ZED X One Core Specifications

Open in ClaudeOpen in ChatGPT

This page gathers the hardware specifications of the ZED X One Core monocular camera module. The reference document is the official ZED X One Core datasheet.

Image sensor

The ZED X One Core is built around an AR0234 1/2.6” 2.3 MP RGB global shutter sensor, which provides good low-light capabilities and distortion-free images of fast-moving objects.

FeatureValue
Sensor type1/2.6” 2.3 MP RGB
Array size1928 x 1208 pixels
Pixel size3 µm x 3 µm
Chief Ray Angle (CRA)
Recommended lens CRA0° ± 3°
ShutterElectronically synchronized global shutter
Image format16:10
Output resolution1920x1200 @15/30/60 fps
1920x1080 @15/30/60 fps (cropping mode)
960x600 @15/30/60/120 fps (binning mode)
Output formatRAW10 (V4L2) / YUV 4:2:0 (Argus)
Max. S/N ratio38 dB
Dynamic range71.4 dB
Sensitivity22.3 Ke/Lux·s
Camera controlExposure, analog and digital gain, gamma, white balance, saturation, sharpness, denoising, brightness, contrast

Optics

FeatureFisheye lensWide lensNarrow lens
Focal length1.38 mm (0.054”)2.2 mm (0.086”)4.6 mm (0.18”)
Field of view204° (H) x 137° (V) x 218° (D)110° (H) x 80° (V) x 120° (D)73° (H) x 45° (V) x 87° (D)
Aperturef/2.0f/2.2f/2.0
Distortion< 18.80% (F-θ)< 4.39%-6.7%

Cameras purchased with one of these lens options are factory focused and calibrated. The no lens version is meant for integrators mounting their own optics: in that case, focusing and intrinsic calibration are performed by the integrator. A stereo rig built from two cameras always requires an extrinsic calibration.

Motion sensor

The integrated BOSCH BMI088 IMU is a high-performance 6-axis inertial sensor with a 16-bit triaxial accelerometer and gyroscope, providing orientation and motion detection of the camera. Its high vibration robustness and temperature stability make it suitable for harsh industrial robotics environments.

FeatureValue
Motion sensorBOSCH BMI088 IMU
Accelerometer range± 12 G
Accelerometer resolution0.36 mg
Accelerometer noise density2.3 mg
Gyroscope range± 1000 dps
Gyroscope resolution0.03 dps
Gyroscope noise density0.20 dps
Sensitivity error± 0.5%
Output data rate200 Hz

You can access the sensor data through the Sensors API of the ZED SDK.

Sensor positions

The IMU origin is vertically and horizontally aligned with the optical center of the image, with a depth offset of -5.92 mm along the Z axis. The offset specifies the location of the IMU origin with respect to the center of the image plane.
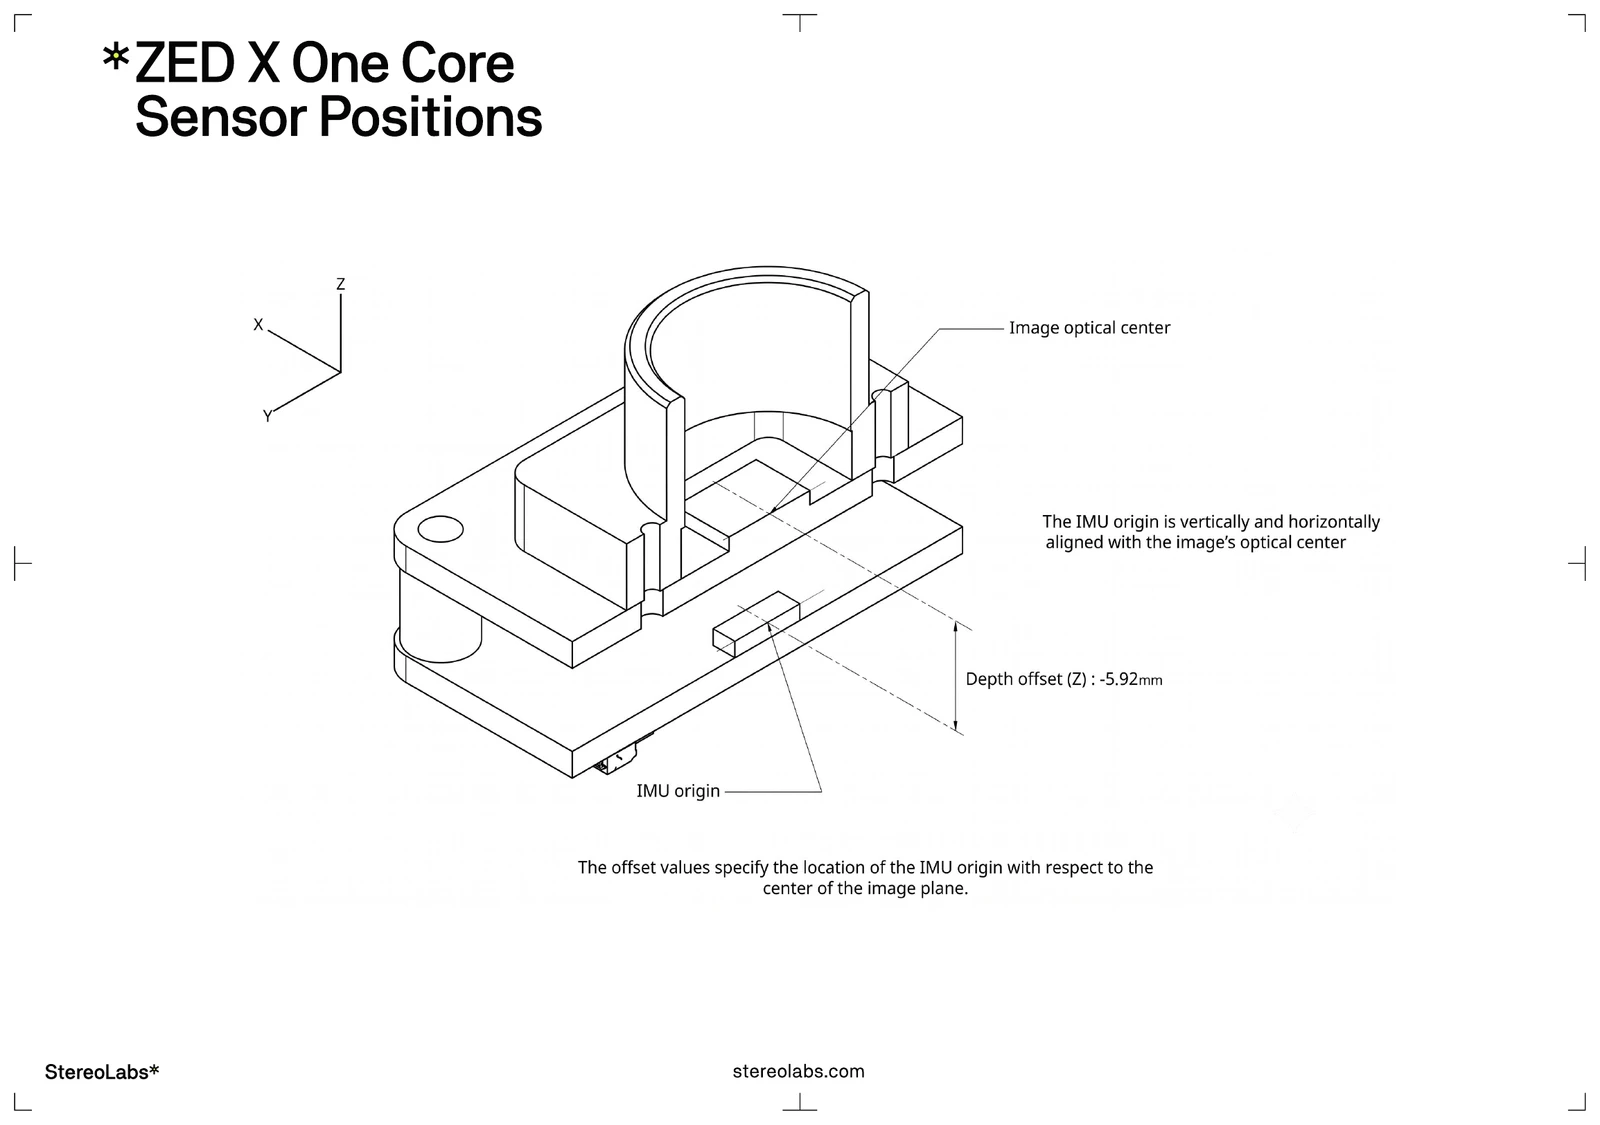
ZED X One Core sensor positions

Physical specifications

FeatureValue
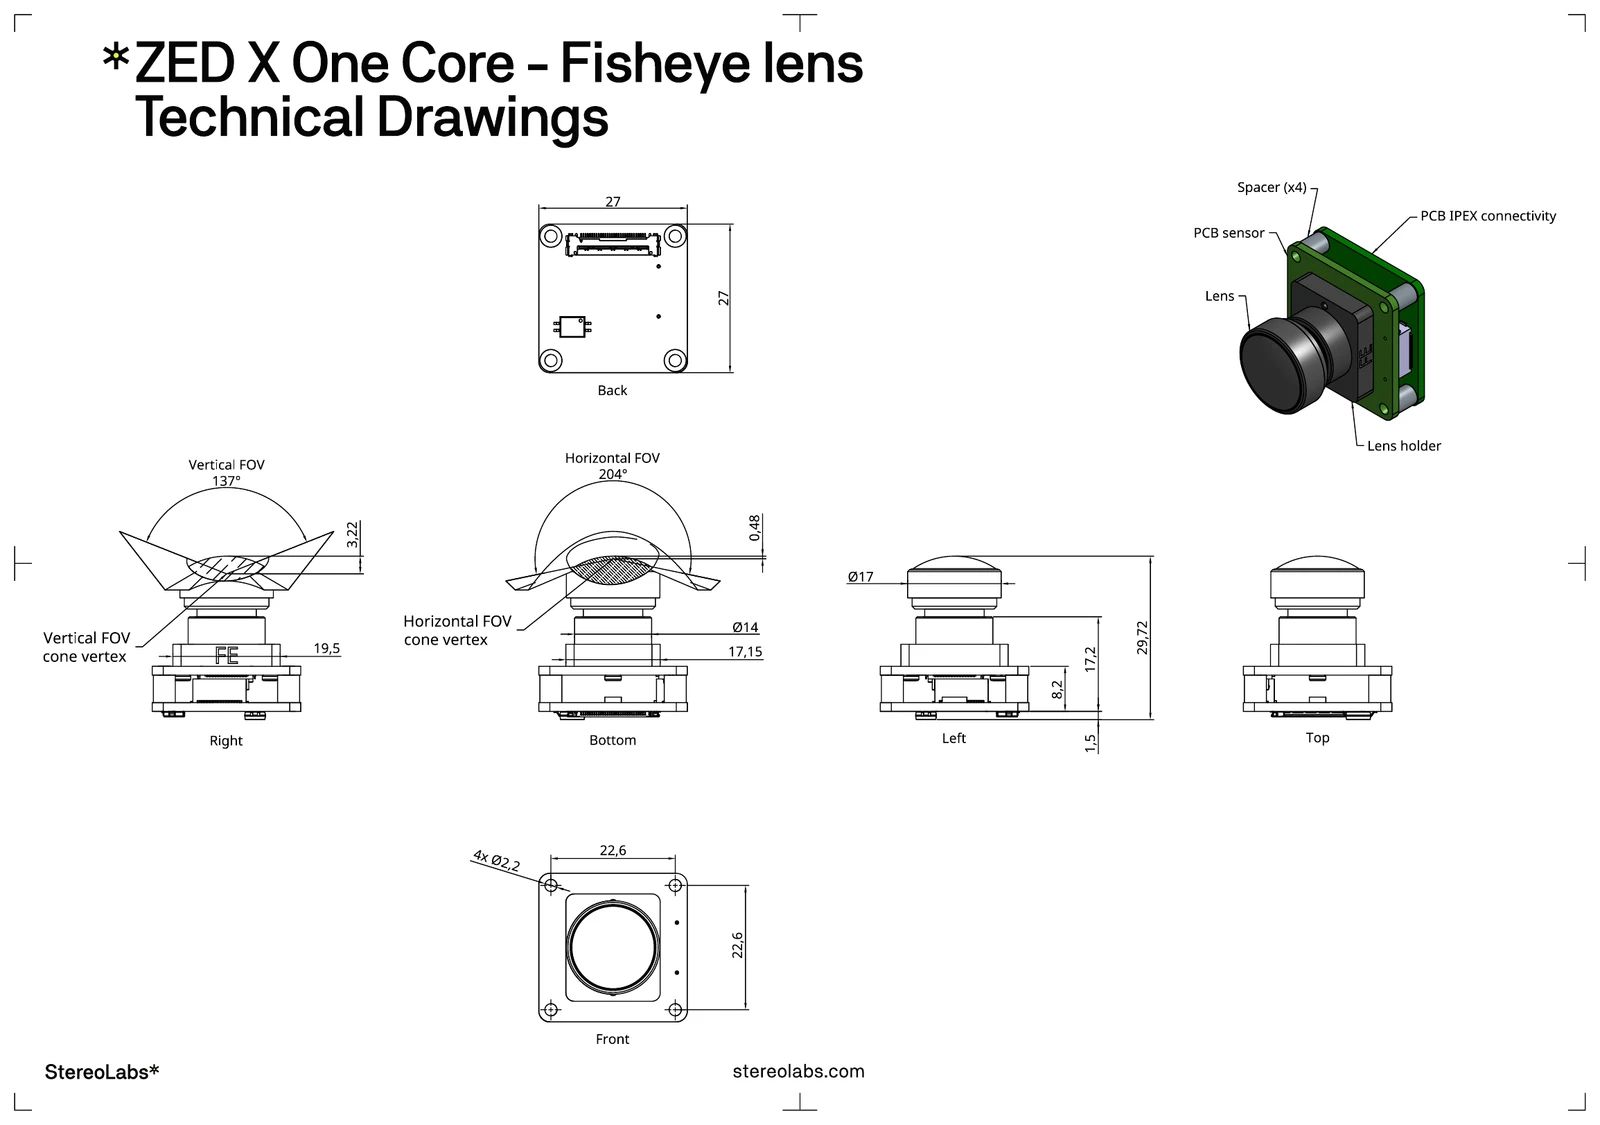
DimensionsFisheye lens: 27 x 27 x 29.72 mm (1.06 x 1.06 x 1.17”)
Wide lens: 27 x 27 x 34.52 mm (1.06 x 1.06 x 1.34”)
Narrow lens: 27 x 27 x 31.27 mm (1.06 x 1.06 x 1.23”)
WeightFisheye lens: 17 g (0.04 lb.)
Wide lens: 19 g (0.04 lb.)
Narrow lens: 14 g (0.03 lb.)
Mounting4x Ø2.2 mm diameter holes
InterfaceMIPI CSI-2, Micro I-PEX cable
Operating temperature-20°C to +60°C (-4°F to 140°F)
PowerPower via MIPI, 0.8 W (240 mA @ 3.3 VDC)
Warranty2-year hardware warranty

Technical drawings

ZED X One Core fisheye lens technical drawings

System requirements

The ZED X One Core requires an NVIDIA® Jetson AGX Orin™ Developer Kit (J12) equipped with a ZED Link MIPI Quad capture card (4x MIPI camera inputs, 75 x 40 mm), or an NVIDIA® Jetson AGX Thor™ with Holoscan Sensor Bridge, for its MIPI CSI-2 connection. See the Recommended Specifications for ZED SDK page for the up-to-date host requirements.

Minimum ZED SDK version

Camera modelMinimum ZED SDK version
ZED X One Corev5.5

Part numbers

ModelSKU
ZED X One Core - No lensZED-411013
ZED X One Core - Narrow lens (4.6 mm)ZED-412013
ZED X One Core - Wide lens (2.2 mm)ZED-413013
ZED X One Core - Fisheye lens (1.38 mm)ZED-414013

Standards and compliance

CertificateRegion
REACHEuropean Union
RoHS 3European Union
FeatureValue
Country of originFrance
HS code85258940
ECCNEAR99

The compliance certificates are available on the StereoLabs certificates page.